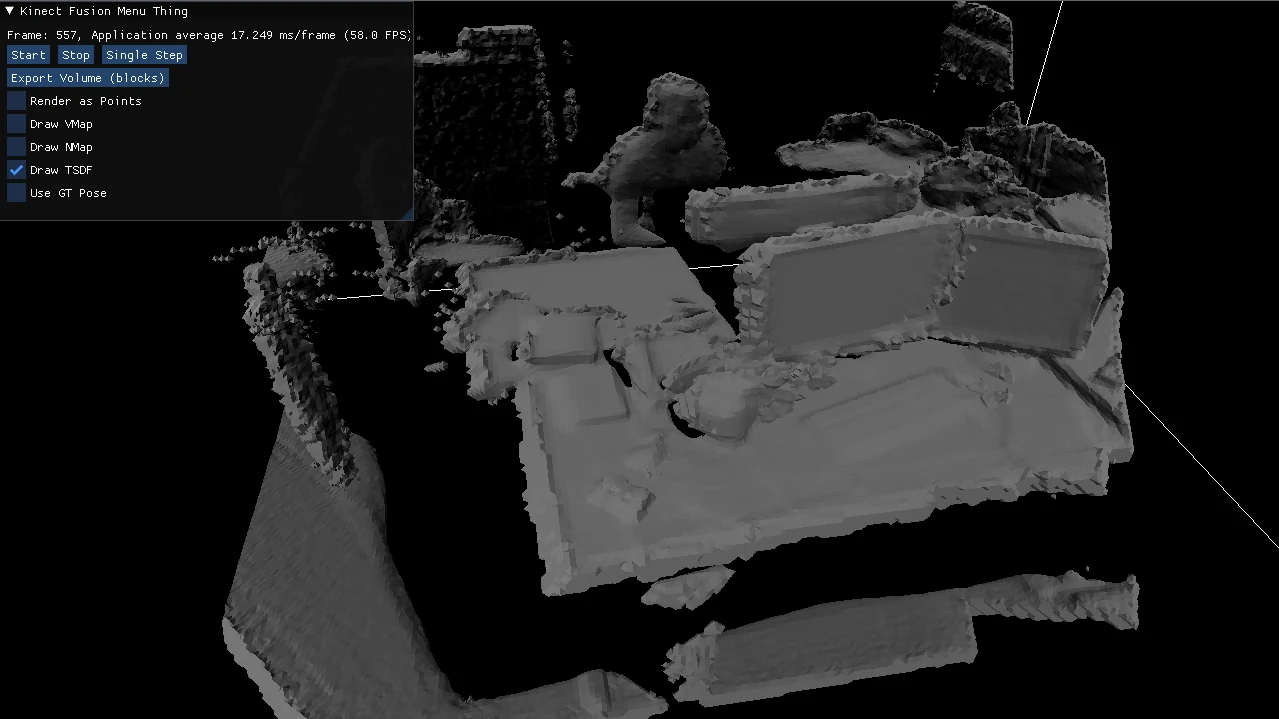
During my semester abroad at the Technical University of Munich in 2020/2021, I collaborated with two graduate students on implementing a real-time 3D reconstruction system for hand-held depth scanners. The full report (PDF) has all the details.
Abstract
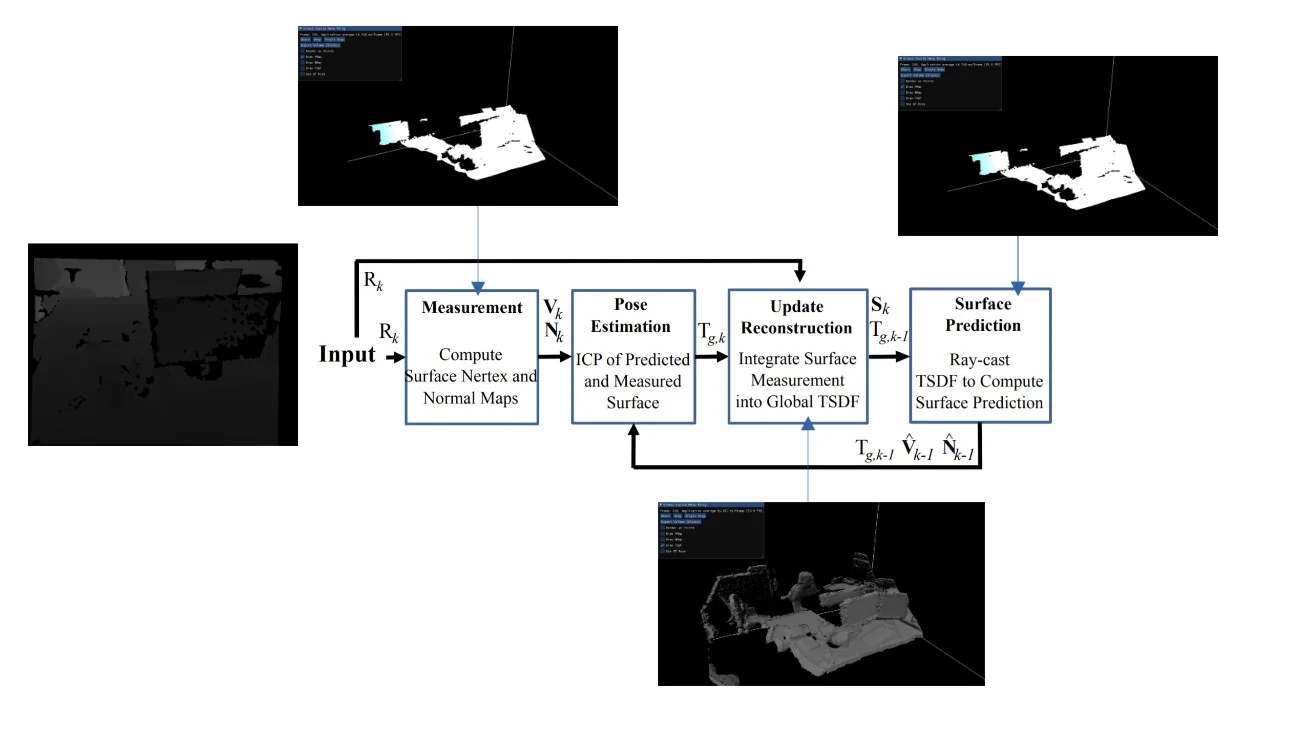
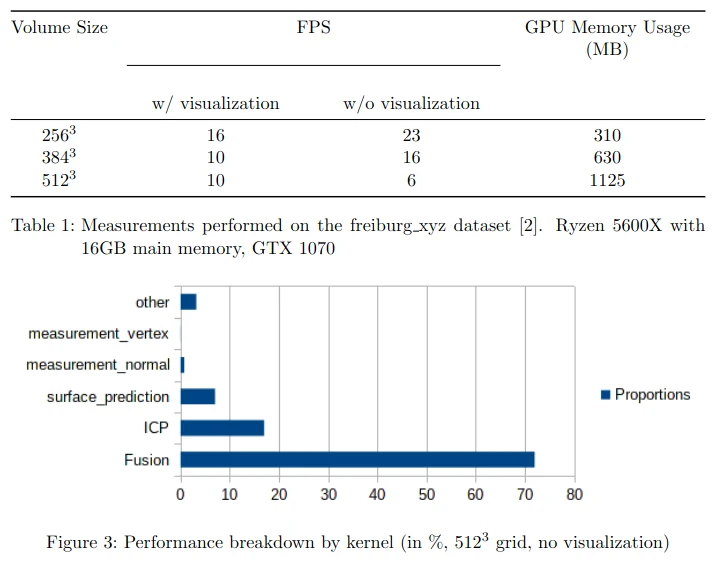
In this report, we first introduce the KinectFusion approach and why it is interesting to implement. Afterward, an overview of the method is given. The main part discusses different implementation details, as well as the GUI and marching cubes implementation. Finally, we briefly go over experimental results and give a conclusion.